With Christopher Grimm, I studied a singular version of the classical brachistochrone problem in which the gravitational potential is proportional to the inverse distance from the origin. The singularity changes the variational problem qualitatively: the globally time-minimizing path need not be a single smooth Euler–Lagrange trajectory.
Travel-time functional
After nondimensionalization, the travel time of an absolutely continuous curve \(\alpha:[0,1]\to\mathbb R^2\) can be written in the form
\[ T[\alpha]=\int_0^1 \frac{\|\alpha'(s)\|}{\sqrt{\|\alpha(s)\|^{-1}-1}}\,ds. \]The admissible curves connect prescribed endpoints. The factor in the denominator is the speed obtained from conservation of energy in an inverse-square gravitational field.
Strong Euler–Lagrange solutions
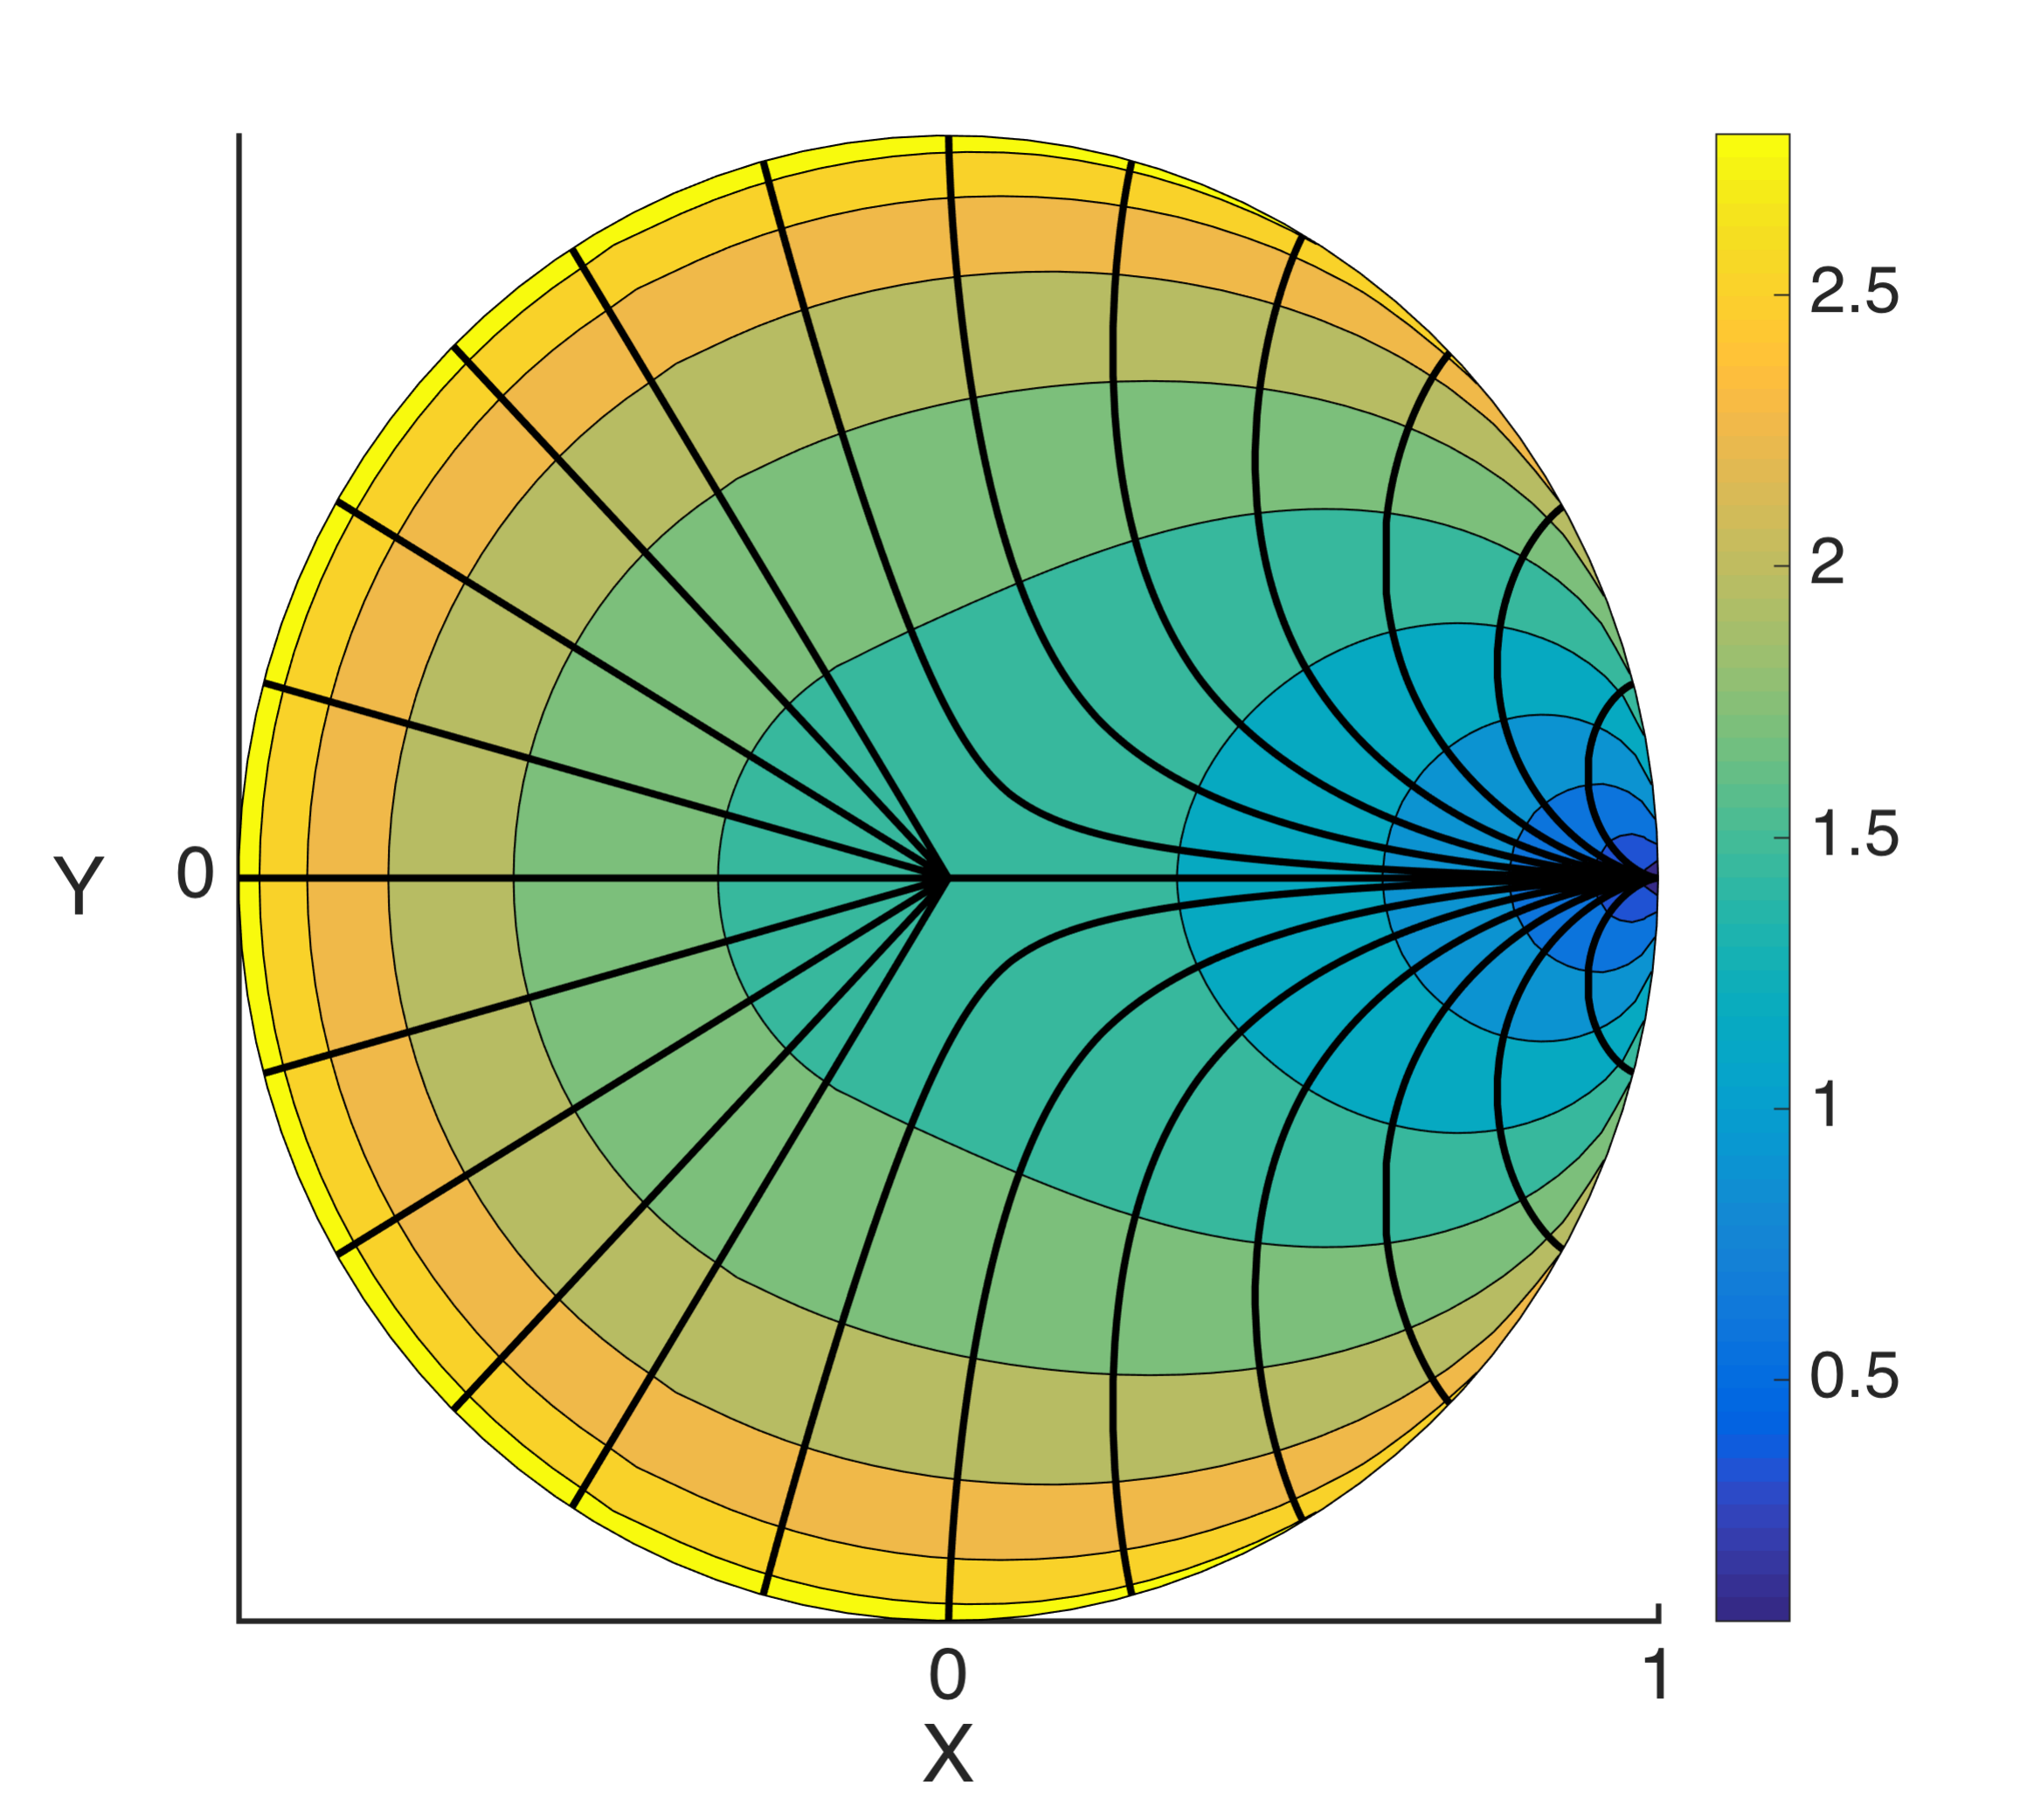
A smooth minimizer must satisfy the Euler–Lagrange equations. Rotational symmetry supplies a first integral analogous to Snell's law in geometrical optics. If the curve is written in polar coordinates \((r,\theta)\), the conserved angular momentum reduces the second-order Euler–Lagrange equation to a first-order relation between \(r\) and \(\theta\). These strong solutions foliate only part of the disk: a forbidden region remains near the singular origin.
Weak solutions through the singularity
The missing minimizing trajectories are obtained by allowing curves to pass through the origin and patching together strong solutions on either side. In the weak variational formulation, the singular point acts as a junction at which classical differentiability is not required. The resulting paths are piecewise smooth but still globally minimize travel time.
This is a useful example of a general principle in the calculus of variations: the Euler–Lagrange equation gives a necessary condition only where enough regularity is already known. Singular minimizers may require a weak formulation before the correct solution class becomes visible.
Connection with Hamilton–Jacobi theory
The minimum travel time defines a value function \(V(x)\). Formally it solves an eikonal/Hamilton–Jacobi equation
\[ |\nabla V(x)|=n(x), \]where the effective refractive index \(n(x)\) is the reciprocal of the local speed. The minimizing curves are characteristics of this equation. The weak brachistochrones that pass through the origin fill the region inaccessible to smooth characteristics and complete the foliation.
Annular regularization
We also remove a small disk of radius \(\varepsilon\) around the singularity and solve the corresponding problem on an annulus. The minimizing path may then run along the inner boundary. As \(\varepsilon\to0\), these annular minimizers converge to the patched weak solutions on the disk. This gives a geometric regularization of the singular problem and provides an independent justification for the weak solution construction.
Reference
- Grimm, C., & Gemmer, J. A. (2017). Weak and strong solutions to the inverse-square brachistochrone problem on circular and annular domains. Involve 10(5), 833–856.